Research Engineer — Control Theory, Computer Vision & ML
German-British Physics graduate (MSc, ETH Zürich) with 3 years of research engineering experience at EPFL CVLab, focused on bridging the gap between control theory, computer vision, and machine learning. Expert in developing high-performance autonomy stacks for high-speed fixed-wing aircraft (100 m/s), with a core strength in translating complex physical systems into tractable optimisation problems.
Featured Projects
AIrcraft
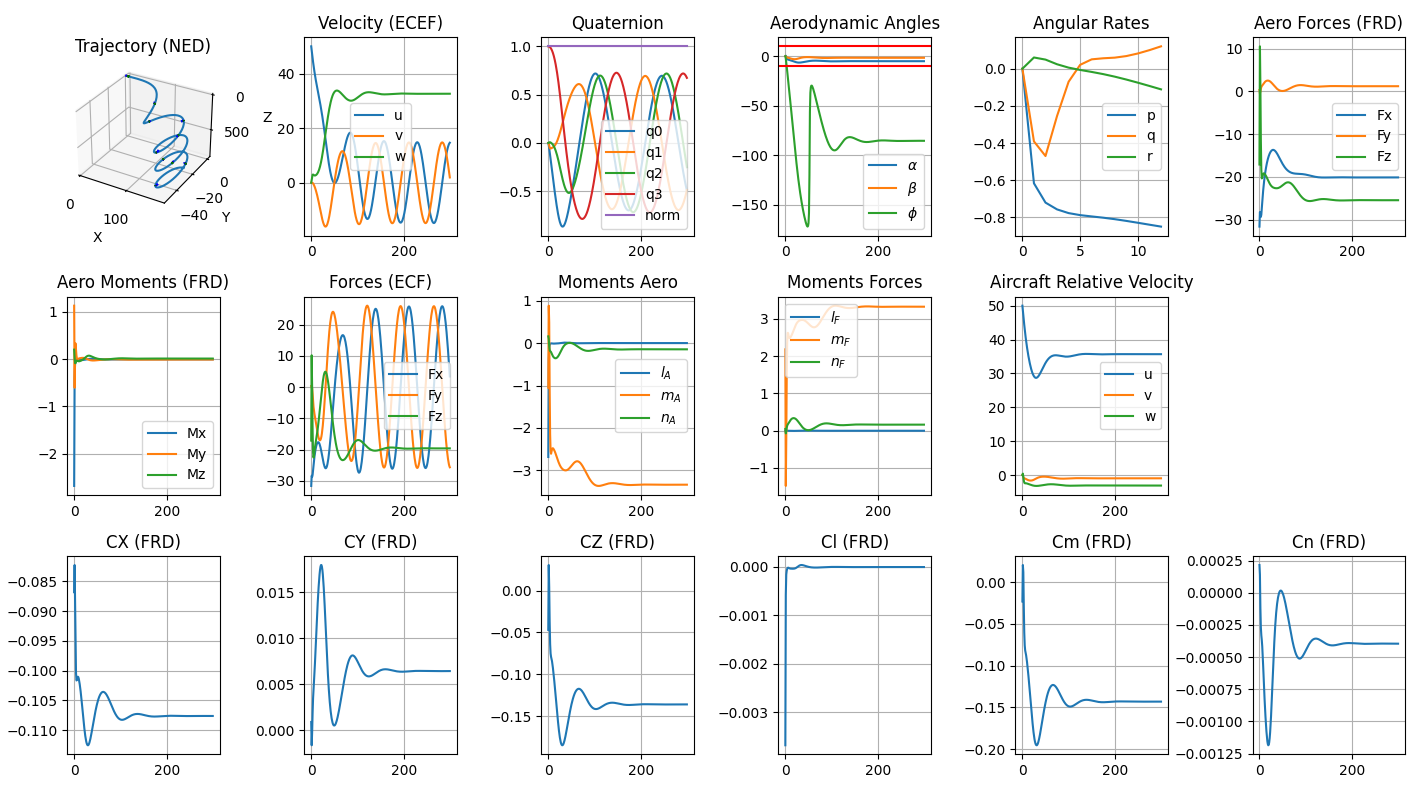
Time-optimal MPC and trajectory optimisation for a fixed-wing drone at 100 m/s, with a differentiable aerodynamic surrogate model.
MARMOT
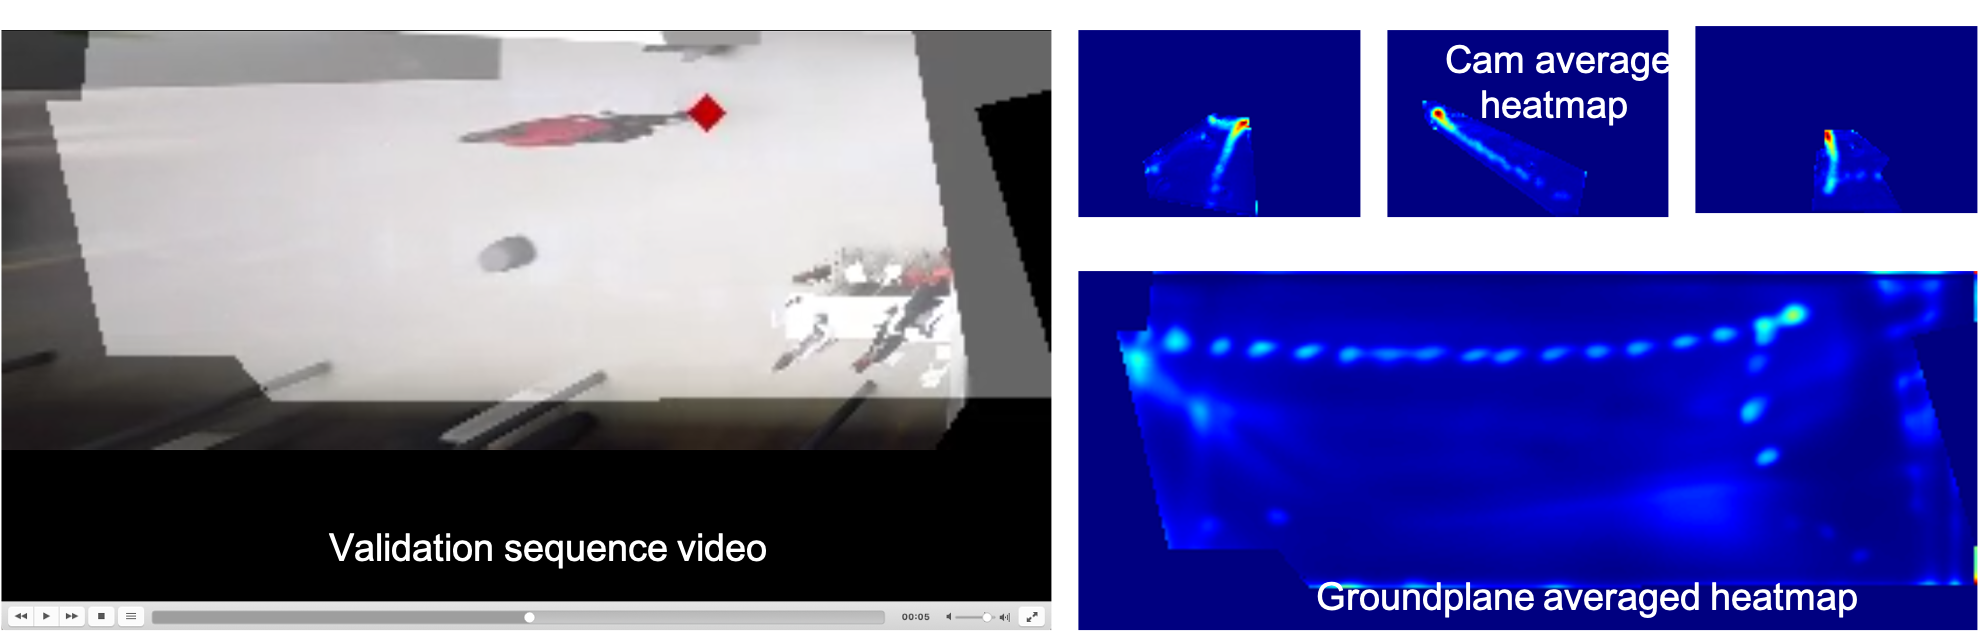
Multi-camera localisation, calibration, and ground-plane pedestrian tracking with automated axis-alignment via RANSAC.
MultiCam-GT
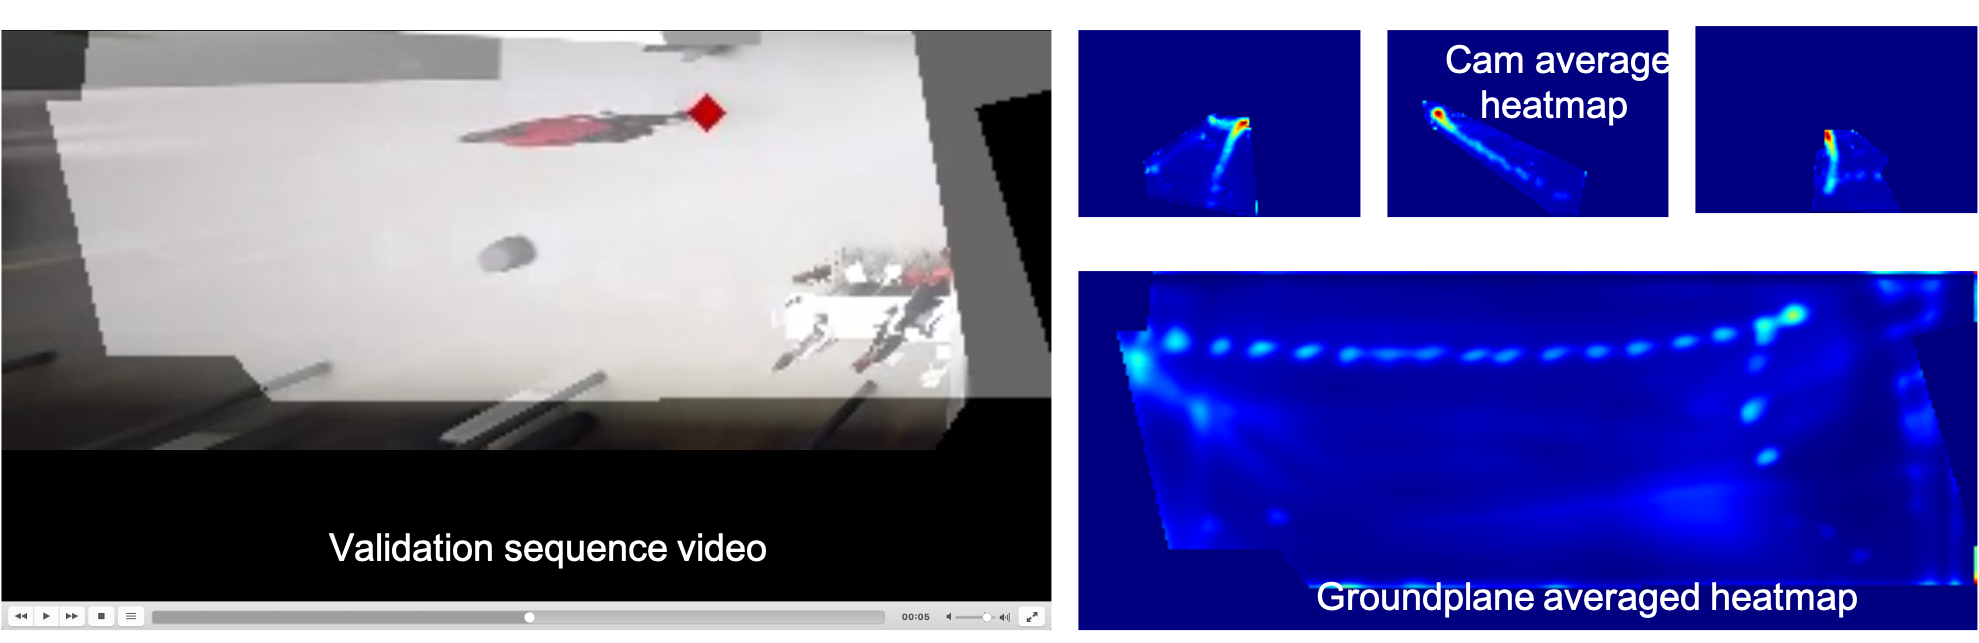
Multi-view annotation tool for the SCOUT dataset — automated tracklet merging reduced manual annotation time by ~90%.
Core Competencies
Control & Simulation
CasADi · Ipopt · SOFA · Trajectory optimisation · MPC · Differentiable surrogate models
Machine Learning
PyTorch · TensorFlow · MMDetection · Graph neural networks · Data-driven control
Computer Vision
Multi-camera systems · OpenSFM · Camera calibration · People tracking · OpenCV
Software Engineering
Python (15 years) · C++ · Django · Git · Docker · RunAI · Slurm · CMake